Aerial obstacle avoidance algorithms
May 25, 2023
These are two obstacle avoidance algorithms I worked on for the Multirotor Robot Design Team at Missouri S&T for the SUAS 2022 competition.
Tangent Line Obstacle Avoidance
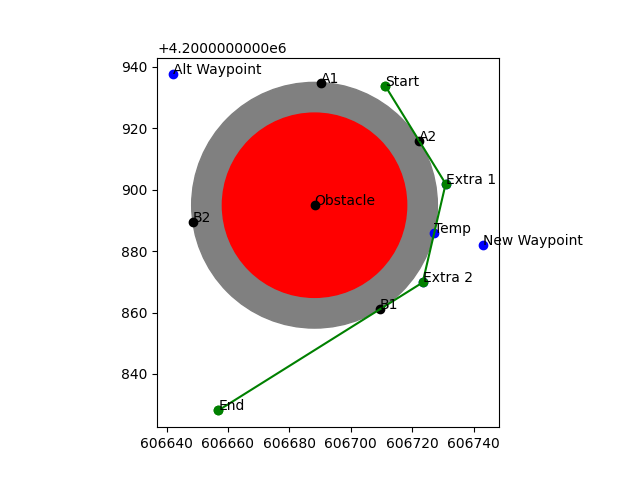
A basic obstacle avoidance algorithm that uses tangent lines to compute new waypoints around circular obstacles to generate a collision-free path.
Read about my full implementation here: Tangent-Line-Obstacle-Avoidance on GitHub.
Informed RRT* Algorithm
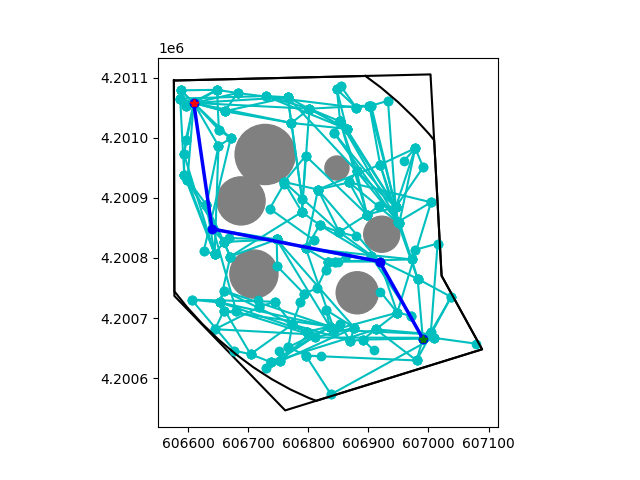
An advanced obstacle avoidance algorithm that implements the Informed RRT* algorithm (Rapidly-exploring Random Trees) to generate a collision-free path between waypoints in a bounded space.
Read about my full implementation here: Informed-RRT-Star-Obstacle-Avoidance on GitHub.